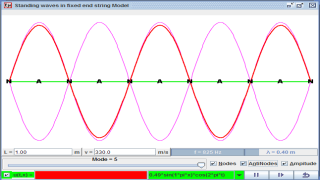
{source}
<?php  require_once JPATH_SITE.'/TTcustom/TT_contentparser.php';\(parameters = array("topicname" => "04waves_12generalwaves", "modelname" => "ejss_model_PICUP_string_frem");echo generateSimHTML(\)parameters, "EJSS");
?>
{/source}
Overview
This document summarizes the key themes and important ideas presented in the provided excerpts. The source describes a computational exercise where students develop and analyze a lattice-elasticity model of a vibrating string. This model, unlike the standard wave equation which is valid only for small amplitudes, allows for the study of nonlinear properties of the string as the amplitude of vibration increases. The exercise is divided into parts, guiding students through building the model, coding a numerical solver, testing its behavior in the low-amplitude limit against analytical predictions, and finally exploring nonlinear effects at larger amplitudes.
Main Themes and Important Ideas
1. Limitations of the Standard Vibrating String Model:
- The traditional description of a vibrating string using the wave equation is accurate only when the amplitude of vibrations is small. The source explicitly states: "The standard description of the behavior of the vibrating string is only valid in the low-amplitude limit."
- This limitation arises from the "small-angle approximation to trigonometric functions" used in deriving the wave equation from a more fundamental model.
2. Introduction of the Lattice-Elasticity Model:
- To overcome the limitations of the standard model, the exercise introduces a lattice-elasticity model. This model represents the string as a series of discrete point masses connected by Hooke's law springs.
- The goal is to "build a lattice-elasticity model of a vibrating string and then study its properties, first verifying that the standard properties predicted by \(v = \sqrt{T/\mu}\) hold in the low-amplitude limit and then studying the nonlinear properties of the vibrating string as the amplitude increases."
- The model's parameters (masses, spring constants, equilibrium length) are related to the macroscopic properties of the string (total mass \(M\), unstretched length \(L\), Young’s modulus \(Y\), and cross-sectional area \(A\)). The "stiffness" \(\gamma \equiv AY\) is defined as a useful parameter.
3. Numerical Calculation of Vibrations:
- A key aspect of the project is the numerical calculation of the string's vibrations using the lattice model. Since the model consists of discrete objects moving under calculable forces, its behavior can be simulated computationally.
- The force between adjacent masses is governed by Hooke's law: "\(\vec{F}{BA} = k (r{AB} - r_0) \hat{r}{AB}\)", where \(k\) is the spring constant, \(r{AB}\) is the distance between masses A and B, and \(r_0\) is the equilibrium length.
- The project requires students to code a numerical solver to simulate the motion of these masses over time.
4. Testing and Verification in the Low-Amplitude Limit:
- The exercise emphasizes the importance of testing the numerical model by comparing its predictions to the analytical results known for the standard vibrating string in the low-amplitude regime.
- Students are instructed to supply initial conditions corresponding to a stretched but unexcited string and then to introduce excitations corresponding to normal modes.
- The analytical solution for the \(n\)-th normal mode is given as "\(y(x, t) = A \sin \frac{n \pi x}{L'} \cos \omega_n t\)", where \(L'\) is the stretched length and \(\omega_n\) is the angular frequency. The relationship between frequency, wavespeed, and wavelength is also mentioned: "\(f_n = \omega_n / 2\pi = n v / 2L'\)".
- The wavespeed \(v\) in this limit is given by "\(v = \sqrt{T / \mu'}\)", where \(T\) is the tension and \(\mu'\) is the linear mass density of the stretched string.
5. Quantitative Measurement of Period:
- To quantitatively compare the simulation with analytical predictions in the low-amplitude limit, students are tasked with measuring the period of the normal modes in their simulation.
- The suggested method involves tracking the vertical velocity of a mass near an antinode and detecting when it completes a full cycle.
- Students are asked to "modify your code to track the period, and measure the period of a normal mode of your choice. How does your result correspond to the analytic prediction in the low-amplitude regime for different normal modes? Vary the tension, mass, Young’s modulus, and length, and see if your simulation behaves as expected."
6. Exploring Nonlinearity at Large Amplitudes:
- The ultimate goal of using the lattice model is to investigate the behavior of the vibrating string beyond the low-amplitude limit, where nonlinear effects become significant.
- The source highlights that the standard wave equation relies on approximations that break down at larger amplitudes: "deriving this equation from our model requires making the small-angle approximation to trigonometric functions, and this is only valid in the limit \(A \rightarrow 0\)."
- The exercise encourages students to explore phenomena that are not captured by the ideal wave equation, emphasizing the power of numerical simulation: "Now it’s time to do something the pen-and-paper crowd can’t do (without a great deal of pain): get away from that limit."
7. Dependence on the Number of Masses (N):
- The source prompts students to consider the impact of the discretization (number of masses \(N\)) on the simulation's behavior.
- Questions are raised about whether \(N\) should affect the behavior and whether a large \(N\) is more critical for modeling low or high normal modes. This encourages thinking about the convergence of the discrete model to the continuous string.
Key Variables and Relationships
- \(v\): Wavespeed
- \(T\): Tension in the string
- \(\mu\): Linear mass density (mass per unit length)
- \(N\): Number of segments (and \(N+1\) masses) in the lattice model
- \(L\): Unstretched length of the string
- \(L'\): Stretched length of the string
- \(M\): Total mass of the string
- \(Y\): Young's modulus
- \(A\): Cross-sectional area
- \(\gamma \equiv AY\): Stiffness
- \(m\): Mass of each point mass in the model (\(m = \rho \cdot length / N\), where \(\rho\) is density)
- \(r_0\): Equilibrium length of each spring in the model (\(r_0 = length / N\))
- \(k\): Spring constant of each spring in the model (\(k = stiffness \cdot N / length\))
- \(r_{AB}\): Distance between masses A and B
- \(\hat{r}_{AB}\): Unit vector from A to B
- \(\vec{F}_{BA}\): Force on mass B due to mass A
- \(y(x, t)\): Transverse displacement of the string at position \(x\) and time \(t\)
- \(n\): Mode number
- \(A\): Amplitude of vibration
- \(\omega_n\): Angular frequency of the \(n\)-th normal mode
- \(f_n\): Frequency of the \(n\)-th normal mode
Conclusion
The provided excerpts outline a comprehensive project designed to deepen students' understanding of vibrating strings by moving beyond the simplified linear model. By building and simulating a lattice-elasticity model, students can explore the validity limits of the standard wave equation and investigate the complex nonlinear behavior that arises at larger amplitudes. The exercise emphasizes the connection between microscopic and macroscopic properties, the power of numerical methods in physics, and the importance of verifying computational results against known analytical solutions.
Study Guide: Lattice Model of a Vibrating String
Key Concepts:
- Lattice Elasticity: Modeling a continuous elastic material as a discrete lattice of point masses connected by springs.
- Low-Amplitude Limit: The regime where the displacement of the string is small, and linear approximations are valid.
- Nonlinear Properties: Behaviors of the vibrating string that emerge when the amplitude is large, and linear approximations break down.
- Normal Modes: Specific patterns of vibration in which all parts of the system oscillate with the same frequency and a fixed phase relationship.
- Wave Speed: The speed at which a wave propagates through a medium, determined by the medium's properties (tension and mass density in a string).
- Hooke's Law: The force needed to extend or compress a spring by a distance x is proportional to that distance (F = -kx).
- Small-Angle Approximation: Approximations for trigonometric functions (sin θ ≈ θ, cos θ ≈ 1, tan θ ≈ θ) that are valid when the angle θ is small.
- Numerical Simulation: Using computational methods to model the behavior of a physical system over time.
- Energy Conservation: In an ideal system without energy loss, the total energy (kinetic + potential) remains constant.
- Period of Oscillation: The time it takes for one complete cycle of a vibration.
- Antinode: A point on a standing wave with maximum amplitude.
- Young's Modulus (Y): A measure of a material's stiffness or resistance to elastic deformation under tension or compression.
- Stiffness (γ): Defined as the product of the cross-sectional area (A) and Young's modulus (Y) of the string (γ = AY).
- Mass Density (μ): The mass per unit length of the string.
- Tension (T): The force exerted along the length of the stretched string.
- Equilibrium Length (r0): The unstretched length of each spring in the lattice model.
- Spring Constant (k): A measure of the stiffness of an individual spring in the lattice model.
- Time Step (dt): The discrete interval of time used in a numerical simulation.
- Runge-Kutta 2nd Order (RK2): A numerical method for solving ordinary differential equations, often used for simulating physical systems.
Short Answer Quiz:
- What is the primary limitation of the "standard description" of a vibrating string mentioned in the text? Why is it considered a limitation?
- Explain how the lattice-elasticity model represents a continuous vibrating string. What are the fundamental components of this model?
- According to the provided code excerpts, what is the role of the get_forces function in the simulation? What forces are being calculated?
- Describe the purpose of the evolve_rk2 function. Why is it important for accurately simulating the motion of the string?
- How are the microscopic properties (r0, m, k) of the lattice model related to the macroscopic properties (length, density, stiffness) of the actual string?
- What is the significance of the tension (T) in the context of a vibrating string, and how does it relate to the stretched length (Ls) in the simulation?
- In the context of Part 3 (Testing), what initial conditions are suggested for simulating a stretched but unexcited string? Describe the positions and velocities of the masses.
- Explain the concept of normal modes in a vibrating string. How are they mathematically represented in the provided text (Equation 6)?
- According to Part 5, how can one experimentally measure the period of a specific normal mode in the numerical simulation? What should be tracked?
- What fundamental assumption needs to be made to derive the ideal wave equation from the lattice model? Why does going beyond the low-amplitude limit introduce complexities?
Answer Key:
- The standard description is only valid in the low-amplitude limit. This is a limitation because it fails to accurately predict the behavior of a vibrating string when the amplitude of oscillations becomes significant.
- The lattice-elasticity model represents the string as a series of discrete point masses connected by Hooke's law springs. These masses mimic small segments of the string, and the springs represent the elastic forces between these segments.
- The get_forces function calculates the forces acting on each mass in the lattice. It determines the force exerted by each neighboring spring based on the distance between the connected masses and the spring's equilibrium length.
- The evolve_rk2 function updates the positions and velocities of the masses over a small time step using the Runge-Kutta 2nd order method. This method provides a more accurate way to numerically integrate the equations of motion compared to simpler methods.
- The equilibrium length r0 is the total length divided by the number of segments (N), the mass m of each point mass is the total mass (density * length) divided by N, and the spring constant k is the stiffness multiplied by N and divided by the length.
- Tension is the force stretching the string and is crucial for wave propagation. In the simulation, it contributes to the stretched length Ls, which is the unstretched length plus the extension due to the tension and stiffness.
- The initial conditions for a stretched but unexcited string involve placing the masses along the x-axis, evenly spaced between the fixed endpoints at a distance L'. All initial velocities (vx and vy) of the masses should be zero.
- Normal modes are specific patterns of vibration where each point on the string oscillates sinusoidally with a common frequency. Mathematically, they are represented by sinusoidal functions in space (sin(nπx/L')) and time (cos(ωnt)), with 'n' being the mode number.
- To measure the period, one should select a mass near an antinode of the desired mode and monitor its vertical velocity (vy). A full period is completed when the velocity changes from positive (upward motion) to negative (downward motion) and then back to positive again.
- The ideal wave equation is derived by making the small-angle approximation. Going beyond this limit introduces nonlinear terms because the exact trigonometric functions become important, leading to amplitude-dependent frequencies and potential coupling between normal modes.
Essay Format Questions:
- Discuss the advantages and limitations of using a lattice-elasticity model to simulate a continuous vibrating string. How does the number of discrete masses (N) in the model affect the accuracy and computational cost of the simulation?
- Explain the relationship between the macroscopic properties of a vibrating string (tension, mass density, Young's modulus, length) and the microscopic parameters of the lattice model (mass of point masses, equilibrium length of springs, spring constant). How are these parameters chosen to ensure the model accurately represents the physical string?
- Describe the process of numerically simulating the motion of the vibrating string using the provided code excerpts. Focus on the roles of the get_forces and evolve_rk2 functions and the importance of the time step (dt) in the accuracy and stability of the simulation.
- Analyze the concept of normal modes in the context of both the ideal wave equation and the lattice model of a vibrating string. How do the predicted frequencies of normal modes compare between the two approaches, especially in the low-amplitude limit? What deviations might occur at larger amplitudes?
- Explore the significance of the "low-amplitude limit" in the study of vibrating strings. How does moving beyond this limit, as suggested in Part 6, reveal nonlinear properties of the string's behavior that are not captured by the ideal wave equation? Provide examples of such nonlinear effects that might be observed in the simulation.
Glossary of Key Terms:
- Lattice Elasticity: A method of modeling the elastic behavior of a continuous material by representing it as a discrete network (lattice) of interconnected particles (masses) and springs.
- Low-Amplitude Limit: The condition where the displacements or oscillations in a system are small enough that linear approximations of the governing equations are sufficiently accurate.
- Nonlinearity: In the context of vibrations, it refers to behaviors where the restoring force is not directly proportional to the displacement, often occurring at larger amplitudes. This can lead to amplitude-dependent frequencies and interactions between different modes of vibration.
- Normal Mode: A specific pattern of oscillation of a system in which all parts of the system move sinusoidally with the same frequency and a fixed phase relationship. For a string fixed at both ends, these modes are characterized by integer numbers of half-wavelengths fitting within the string's length.
- Wave Speed: The speed at which a disturbance or wave propagates through a medium. For a stretched string, it is determined by the square root of the ratio of tension to mass per unit length.
- Hooke's Law: A principle stating that the force needed to extend or compress a spring by a distance is proportional to that distance. Mathematically expressed as F = -kx, where F is the force, k is the spring constant, and x is the displacement from the equilibrium position.
- Small-Angle Approximation: Approximations of trigonometric functions that are valid when the angle is small (typically less than about 0.2 radians or 11.5 degrees). The common approximations are sin(θ) ≈ θ, cos(θ) ≈ 1, and tan(θ) ≈ θ.
- Numerical Simulation: The process of using a computer program to model the behavior of a physical system over time by numerically solving the equations that govern its motion. This often involves discretizing time into small steps.
- Energy Conservation: The principle that the total energy of an isolated system remains constant over time. In a vibrating string model without damping, the sum of kinetic and potential energy should not change.
- Period of Oscillation: The time required for one complete cycle of a periodic motion or vibration. It is the inverse of the frequency.
- Antinode: A point on a standing wave where the amplitude of vibration is maximum. These occur at locations where constructive interference is greatest.
- Young's Modulus (Y): A measure of the stiffness of a solid material. It is defined as the ratio of stress (force per unit area) to strain (fractional deformation) in a material under tensile or compressive forces.
- Stiffness (γ): In the context of the source material, it is defined as the product of the cross-sectional area (A) and Young's modulus (Y) of the string (γ = AY). It represents the string's resistance to stretching.
- Mass Density (μ): The mass per unit length of a one-dimensional object like a string. It is calculated by dividing the total mass by the total length.
- Tension (T): The force exerted along the length of a taut string or cable. In a vibrating string, tension provides the restoring force that allows waves to propagate.
- Equilibrium Length (r0): The natural or unstretched length of a spring or elastic element in a model. When a spring is at its equilibrium length, it exerts no force.
- Spring Constant (k): A measure of the stiffness of a spring. A higher spring constant indicates a stiffer spring that requires more force to stretch or compress by a given distance.
- Time Step (dt): The small increment of time used in a numerical simulation to advance the system's state. Smaller time steps generally lead to more accurate results but require more computation.
- Runge-Kutta 2nd Order (RK2): A second-order numerical method used to approximate the solution of ordinary differential equations. It is generally more accurate than first-order methods (like Euler's method) while being computationally relatively efficient.
Version
- https://www.compadre.org/PICUP/exercises/exercise.cfm?I=151&A=vibrating-string
- http://weelookang.blogspot.com/2018/06/lattice-elasticity-vibrating-string-and.html
Other Resources
http://physics.bu.edu/~duffy/HTML5/transverse_standing_wave.html
What is the purpose of this simulation model?
This simulation model aims to numerically calculate the vibrations of a stretched string by using a lattice-elasticity model. It allows users to study the string's behavior, first in the low-amplitude limit to verify standard properties, and then to explore the nonlinear properties that emerge as the amplitude of vibration increases.
How does the simulation model represent a continuous string?
The continuous string is modeled as a series of \(N+1\) discrete point masses connected by springs. The two end masses are fixed. The interactions between these masses, governed by Hooke's law springs, approximate the elastic properties of the continuous string. By increasing the number of masses (\(N\)), the model should better approximate the behavior of a real string.
What forces are acting on the masses in the model?
The primary forces acting on each mass (except the fixed ends) are the forces from the two adjacent springs connecting it to its neighbors. These forces are calculated based on Hooke's Law, where the force is proportional to the difference between the current length of the spring and its equilibrium length (\(r_0\)), and directed along the line connecting the two masses.
How are the microscopic properties of the model (m, k, r0) related to the macroscopic properties of the string (M, L, Y, A)?
The microscopic properties are derived from the macroscopic properties to ensure the model accurately represents the string. The mass of each point mass (\(m\)) is the total mass (\(M\)) divided by the number of segments (\(N\)), so \(m = M/N\), or equivalently, \(m = \text{density} \times \text{length} / N\). The equilibrium length (\(r_0\)) of each spring is the unstretched length (\(L\)) divided by \(N\), so \(r_0 = L/N\). The spring constant (\(k\)) is related to the stiffness (\(\gamma = AY\)) and the length, given by \(k = \text{stiffness} \times N / \text{length}\).
What are the initial conditions for a stretched but unexcited string in this model?
For a stretched but unexcited string with endpoints fixed at a distance \(L' > L\), the initial \(y\)-positions (\(y_i\)) and \(y\)-velocities (\(v_{yi}\)) of all the masses would be zero. The initial \(x\)-positions (\(x_i\)) would be distributed uniformly between the fixed endpoints, so \(x_i = i \times (L'/N)\) for \(i\) from 0 to \(N\). The initial \(x\)-velocities (\(v_{xi}\)) would also be zero. This setup represents the string being stretched to a new equilibrium length \(L'\) under tension \(T\), without any initial displacement or velocity in the transverse direction.
How can the period of a normal mode be measured in the simulation?
The period of a normal mode \(n\) can be measured by observing the motion of a mass near an antinode of that mode. If the initial displacement is in the +y direction, one full period is completed when the mass moves down, then back up, and starts to move down again. This can be tracked in the code by monitoring the y-velocity (\(v_y\)) of the chosen mass for a change from positive to negative. The time elapsed between two such changes (separated by a full cycle) represents the period.
How does the amplitude of vibration affect the string's behavior in this model, particularly regarding the ideal wave equation?
The ideal wave equation, which describes noninterfering superpositions of normal modes with amplitude-independent frequencies, is derived using the small-angle approximation. This approximation is only valid when the amplitude of vibration (\(A\)) is very small (\(A \rightarrow 0\)). As the amplitude increases, this approximation breaks down. The simulation, by not relying on this approximation, can reveal nonlinear behaviors such as amplitude-dependent frequencies and the generation of harmonics, which are not predicted by the ideal wave equation.
How does the number of masses (\(N\)) in the model affect the accuracy of the simulation for different normal modes?
The number of masses (\(N\)) influences the model's ability to accurately represent the string's behavior, especially for higher-frequency normal modes. A larger \(N\) provides a finer discretization of the string, allowing the model to better capture the shorter wavelengths associated with high-\(n\) modes. For low-\(n\) normal modes, even a smaller \(N\) might provide a reasonable approximation. However, for accurately modeling the higher harmonics and nonlinear effects that might involve these higher modes, a larger \(N\) is more critical. The computational cost also increases with \(N\).